
Products / SwarmOS
Command & control software
Plan, supervise, and recover coordinated drone missions from one operational interface.
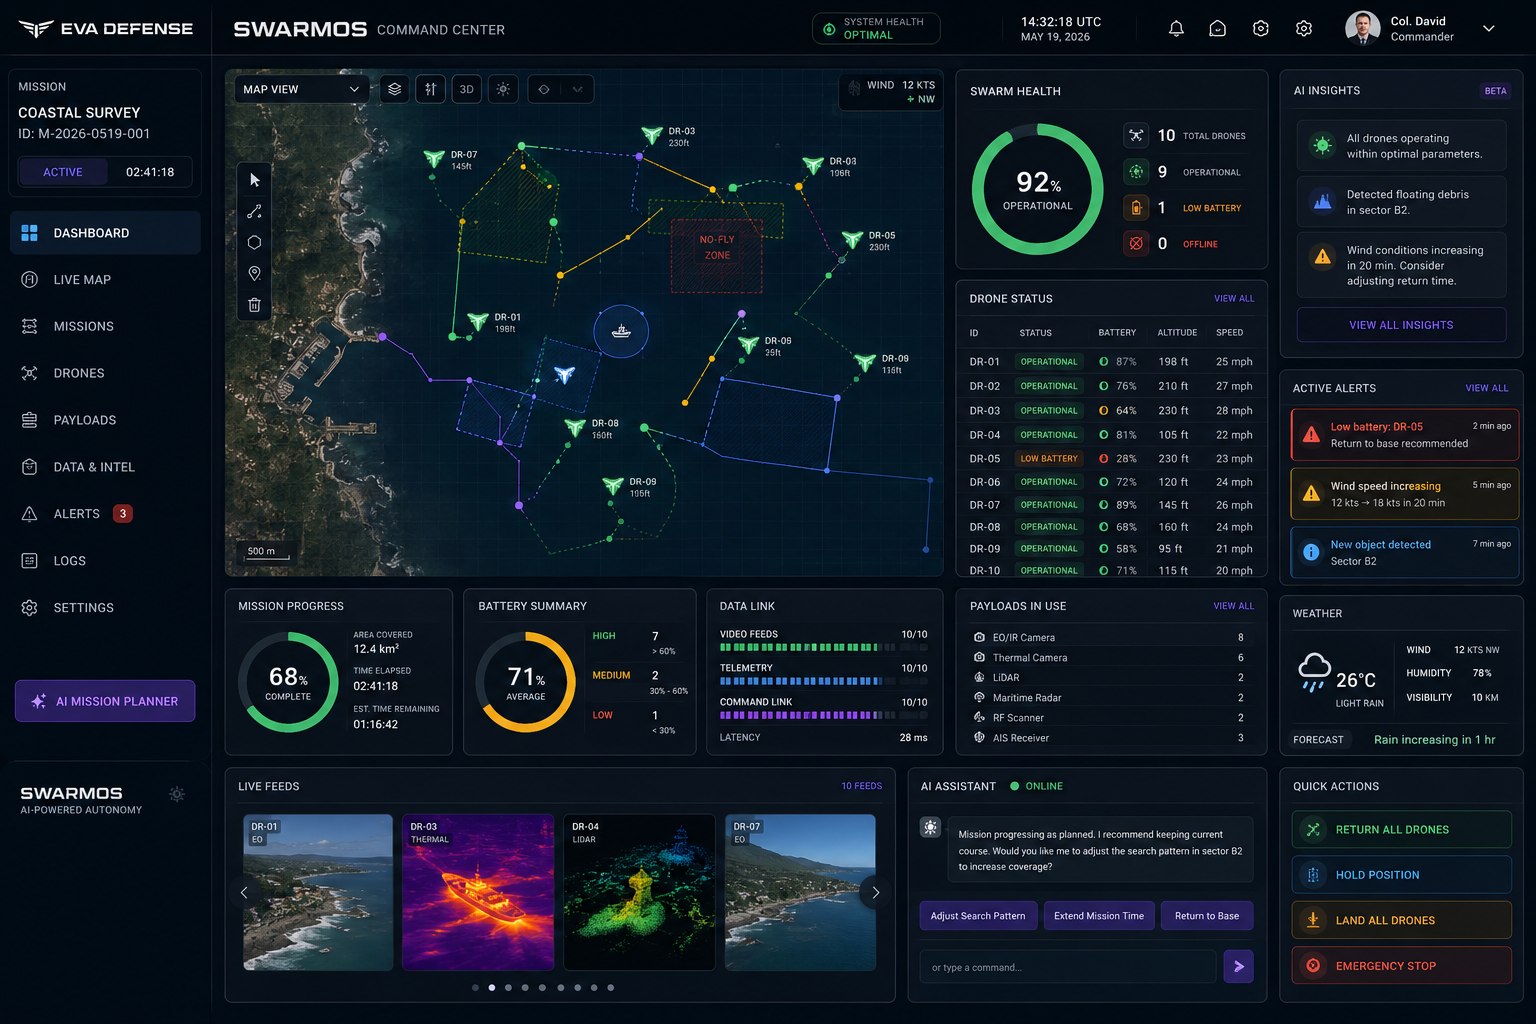
SwarmOS gives defense, public safety, infrastructure, and security teams a single system for mission planning, aircraft assignment, live supervision, sensor awareness, command execution, and recovery — without forcing an operator to manage every aircraft as a separate mission.
5
Aircraft in demonstration swarm
4 Hz
Live telemetry update rate
1
Shared operational picture
The operational value
Built for the swarm, not the single aircraft.
Operational need
SwarmOS response
Buyer impact
Coordinate several aircraft
Assign aircraft to one mission and generate aircraft-specific coverage routes
More coverage without multiplying operator screens
Understand current conditions
Combine map position, health, payload feeds, weather, and alerts
Faster decisions from one current operational picture
Adjust a live mission
Change speed, altitude, task, hold state, duration, or recovery target by aircraft or swarm
Mission plans can respond to conditions without rebuilding the operation
Control risk
Apply per-aircraft limits, geofences, preflight checks, approvals, and recovery rules
Operators receive clear boundaries before a command is transmitted
Prove what happened
Record operator actions, commands, acknowledgements, alerts, and mission outcomes
A complete record supports review, training, and accountability
Designed for operator supervision
Not an autonomous black box.
The platform turns operator intent into visible, validated commands and keeps the human in authority over launch, adjustment, recovery, and mission closure.
Aircraft limits and safety rules remain deterministic even when the AI assistant is used to speed up routine work.
5
Simultaneous MAVLink aircraft
Live
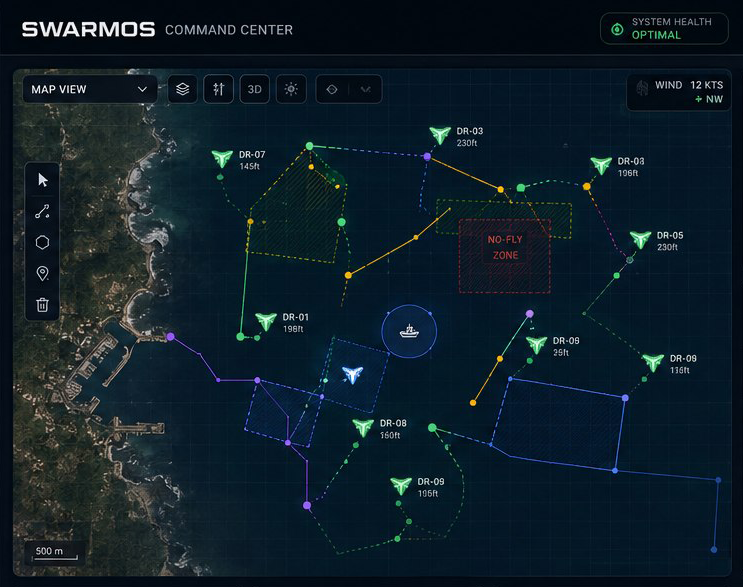
Geospatial mission display
Full
Plan-to-recovery workflow
Development path
From frozen suppliers to production release.
The operator does not have to move between unrelated tools or reconstruct what happened after the fact.
01
Define the mission
Choose the mission type, priority, duration, launch window, country, and city or region.
02
Draw the operating area
Zoom to the location, lock the map scale, draw the geofence, and divide the area into the desired coverage grid.
03
Assign the aircraft
Select available drones by identity and payload. SwarmOS applies each aircraft’s speed, altitude, endurance, and payload limits.
04
Validate readiness
Run preflight checks for aircraft connectivity, battery reserve, GPS, command link, geofence, altitude envelope, payload feeds, and weather.
05
Supervise the mission
Follow live positions, flight modes, tasks, feeds, mission progress, alerts, weather, and data link health from the command center.
06
Adapt in real time
Issue a command to the whole swarm or one aircraft, extend the mission, update tasks, change speed or altitude, hold, resume, or recover.
07
Close with evidence
Return aircraft to the recorded launch point, reconcile outcomes, and retain the mission plan, command log, alerts, tracks, and operator actions.
AI assistant
Natural language commands, validated before they transmit.
Operators can use direct language for supported actions. SwarmOS interprets the request, identifies the target and parameters, validates the command against aircraft limits, and sends the corresponding command through the MAVLink control boundary.
Operator request
"Reduce speed of all drones by 20 percent"
System action
Calculate a new target for each aircraft and send a validated speed command
Operator request
"Lower DR-05 to 300 feet"
System action
Validate DR-05 altitude limits and send the aircraft-specific altitude command
Operator request
"Return DR-03 to base"
System action
Send return-to-launch to DR-03 using the mission launch point
Operator request
"End the mission"
System action
Record mission closure and return all assigned airborne aircraft to launch
Capabilities buyers can evaluate
Everything a supervising operator needs, in one system.
Mission planning
Mission types, operating areas, geofences, grids, launch points, duration, priority, and aircraft assignment.
A repeatable plan tied to a real location and fleet.
Fleet definition
Aircraft identity, type, autopilot, payload, connection, and per-aircraft operating limits.
Commands follow the capabilities of the assigned aircraft.
Live command center
Map, tracks, health, battery, progress, links, feeds, payloads, alerts, weather, and quick actions.
The operator sees mission and aircraft state together.
Swarm and individual control
Speed, altitude, task, hold, return, land, start, resume, and mission duration controls.
The mission can change without losing target clarity.
AI operator assistant
Status summaries, preflight support, command discovery, and typed natural language actions.
Routine work is faster while validation remains explicit.
Sensor feeds
Aircraft-specific EO, IR, thermal, radar, AIS, and RF presentation with feed health and metadata.
Payload awareness stays tied to the aircraft and mission.
Safety controls
Preflight checks, geofence enforcement, battery reserve, link monitoring, per-aircraft limits, and recovery.
Unsafe or unsupported commands can be blocked before transmission.
Command accountability
Command frames, acknowledgements, approvals, audit events, and mission exports.
Supervisors can review who requested what and how the aircraft responded.
Simulation and testing
Real-time multi-aircraft simulation, fault injection, and bridge dry-run behavior.
Teams can evaluate workflows before using flight hardware.
Mission applications
Fits missions where several aircraft must cover an area.
Persistent awareness, changing operator priorities, and repeatable coverage — across five sectors.
Defense & maritime
Geofenced coverage, EO/IR/radar/AIS/RF tasking, live map, return to launch.
Public safety
Rapid area planning, aircraft assignment, thermal feeds, alerts, individual recovery.
Infrastructure
Repeatable grids, payload assignment, mission history, evidence export.
Environmental operations
Persistent coverage, thermal observation, weather, mission extension, route adjustment.
Enterprise security
Scheduled patrols, live feeds, command approvals, incident records, fleet limits.
Example mission
Port security, three aircraft, one operator.
A port security team selects the operating area, draws a grid over the harbor approaches, and assigns three available aircraft with EO/IR, thermal, and AIS payloads. SwarmOS creates separate coverage routes inside the approved area. During the mission, the operator slows the AIS aircraft for contact correlation, raises the EO/IR aircraft for a wider view, and directs the thermal aircraft to hold over a new return. When the mission ends, all three aircraft return to the saved launch point and the command history is retained for review.
Safety and command accountability
Authority, limits, and outcomes stay visible.
SwarmOS applies these controls at the mission and command layer, while leaving immediate flight stabilization and onboard failsafes with the aircraft autopilot.
Aircraft-specific limits
Geofenced operations
Battery reserve
Launch point recovery
Preflight validation
Protected actions
Command lifecycle
Audit and export
Deployment boundary
Where the demonstration ends and integration begins.
Current status
The current product demonstrates the full operating workflow with simulated aircraft and includes a guarded bridge contract for real MAVLink systems. Real command forwarding remains disabled until that integration is deliberately configured.
A production deployment adds an approved MAVSDK edge service, verified aircraft identity mapping, secure links, encoded payload streaming, durable infrastructure, and aircraft-specific testing.
Buyer benefit
This staged model lets a buyer evaluate the interface, mission logic, command model, and safety workflow before connecting flight hardware. It shortens the path from product demonstration to a controlled integration program without pretending that every aircraft behaves the same way.
Open integration boundary
SwarmOS is designed around MAVLink-compatible systems and an external MAVSDK bridge. The browser and mission services use a consistent contract for simulation and connected aircraft, allowing teams to validate the operator workflow before enabling real command forwarding. Aircraft-specific adapters can preserve the same command center while mapping supported behavior to PX4, ArduPilot, payload, and radio systems.
Evaluation and deployment path
From simulation to approved aircraft — same operator workflow.
01
Mission workshop
02
Configured demonstration
03
Integration assessment
04
SITL validation
05
Hardware validation
06
Controlled field evaluation
07
Operational rollout
Why SwarmOS
The questions buyers actually ask.
Can one operator supervise several aircraft?
Can we use different aircraft and payloads?
Aircraft definitions carry their own performance limits, payloads, autopilot identity, and connection settings.
Can we change the mission after launch?
Can we see exactly what commands were sent?
Can we evaluate it before connecting hardware?
Can it connect to real MAVLink systems?
Recommended next step
Schedule a live mission demonstration.
We will configure a representative operating area, mission type, aircraft package, payload mix, and command scenario so your team can evaluate the product against a real operational need.